Joint Manipulation IK/FK – Poppy Humanoid Robotic Arm
Co-development & Implementation: Omar Mostafa (2022)
Tools used: Simulink, Matlab, Arduino, Embedded C, Breadboard, Jumper cables, Electric design, Software Engineering, Solidworks, 3D printing.
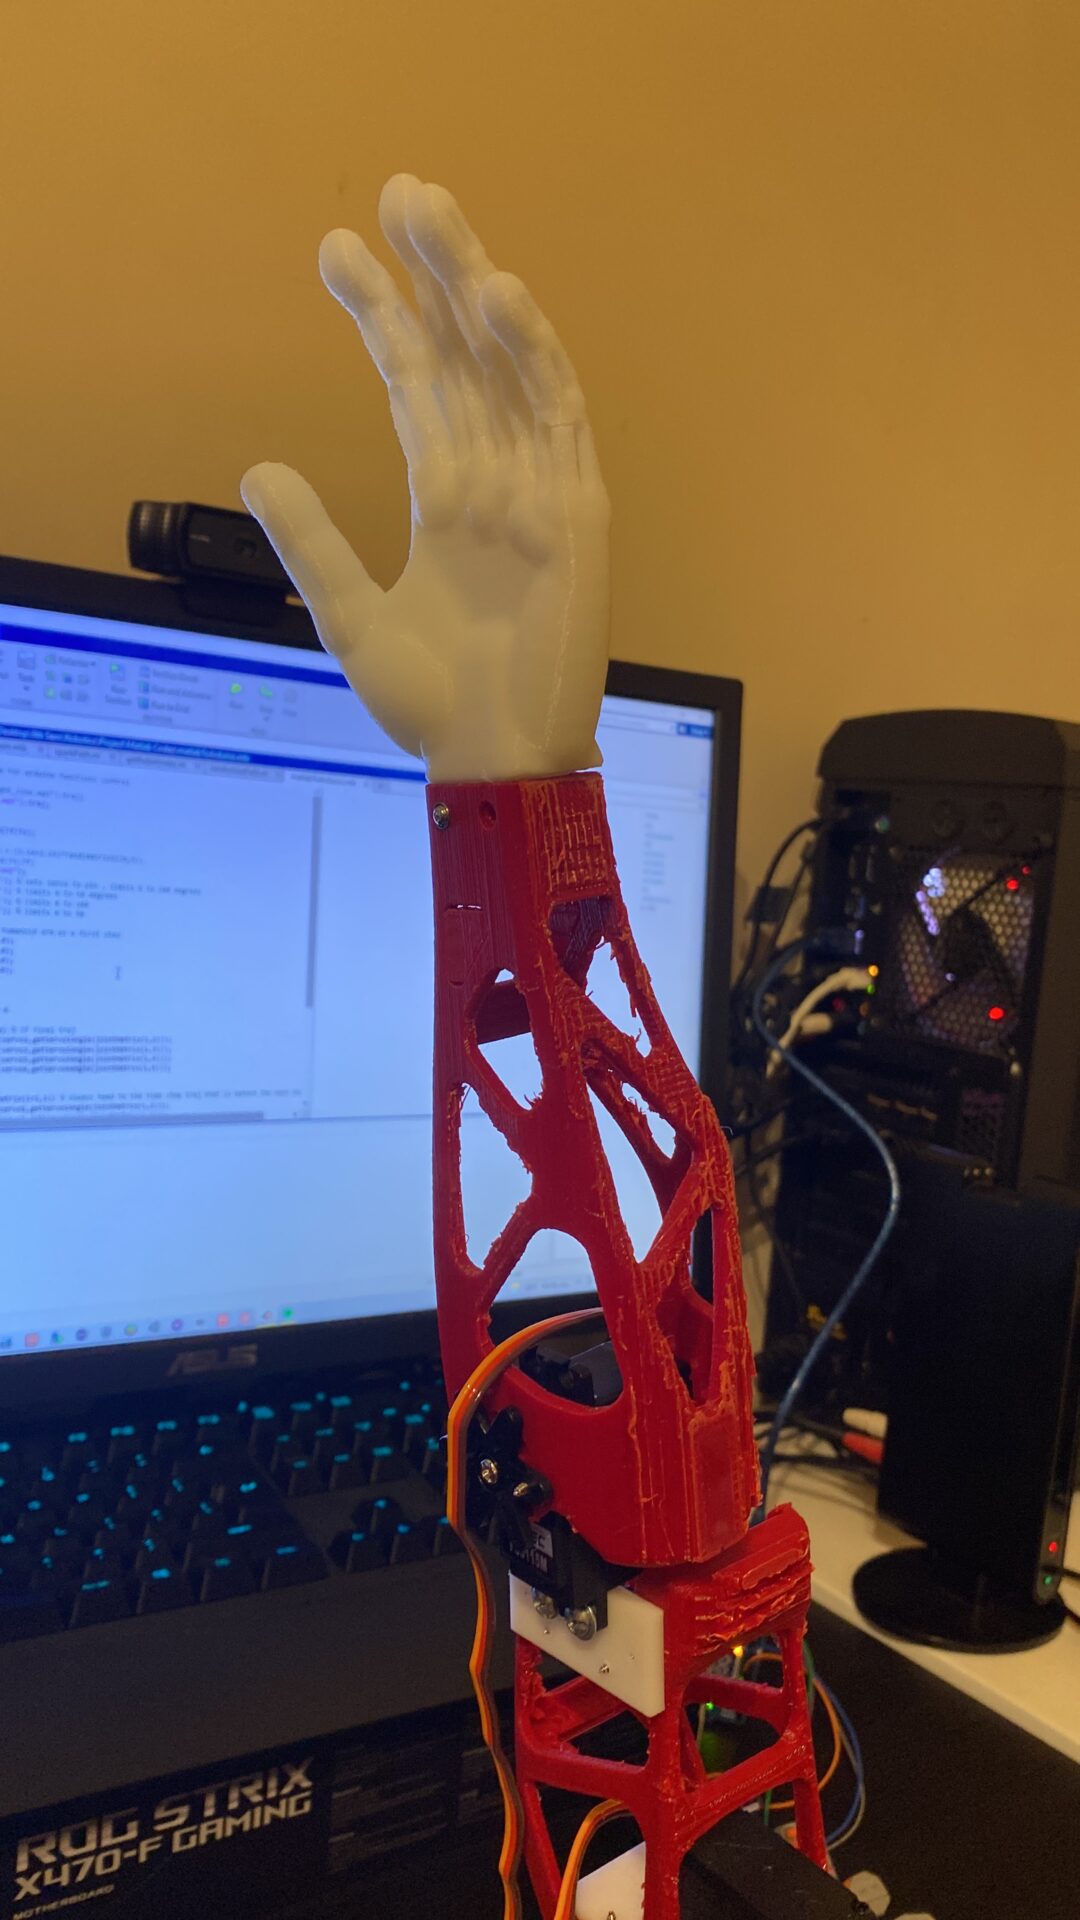
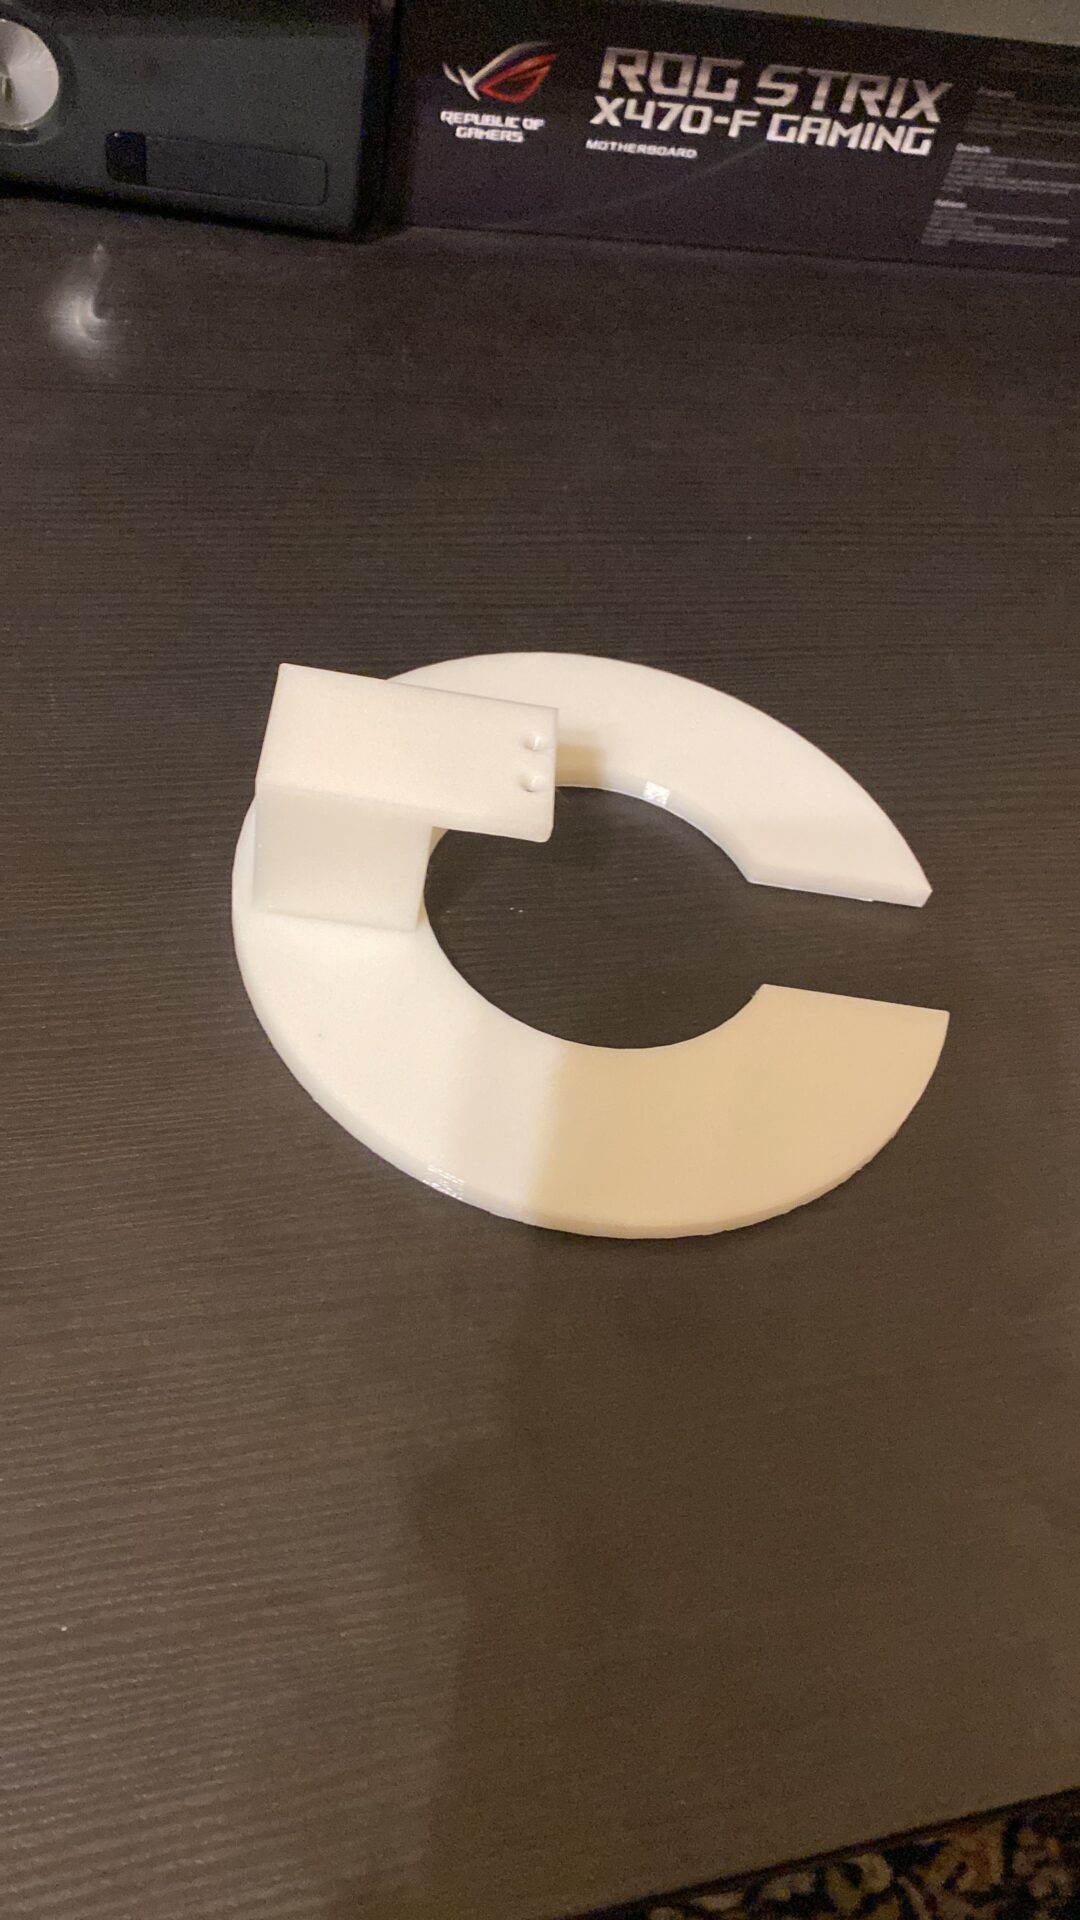
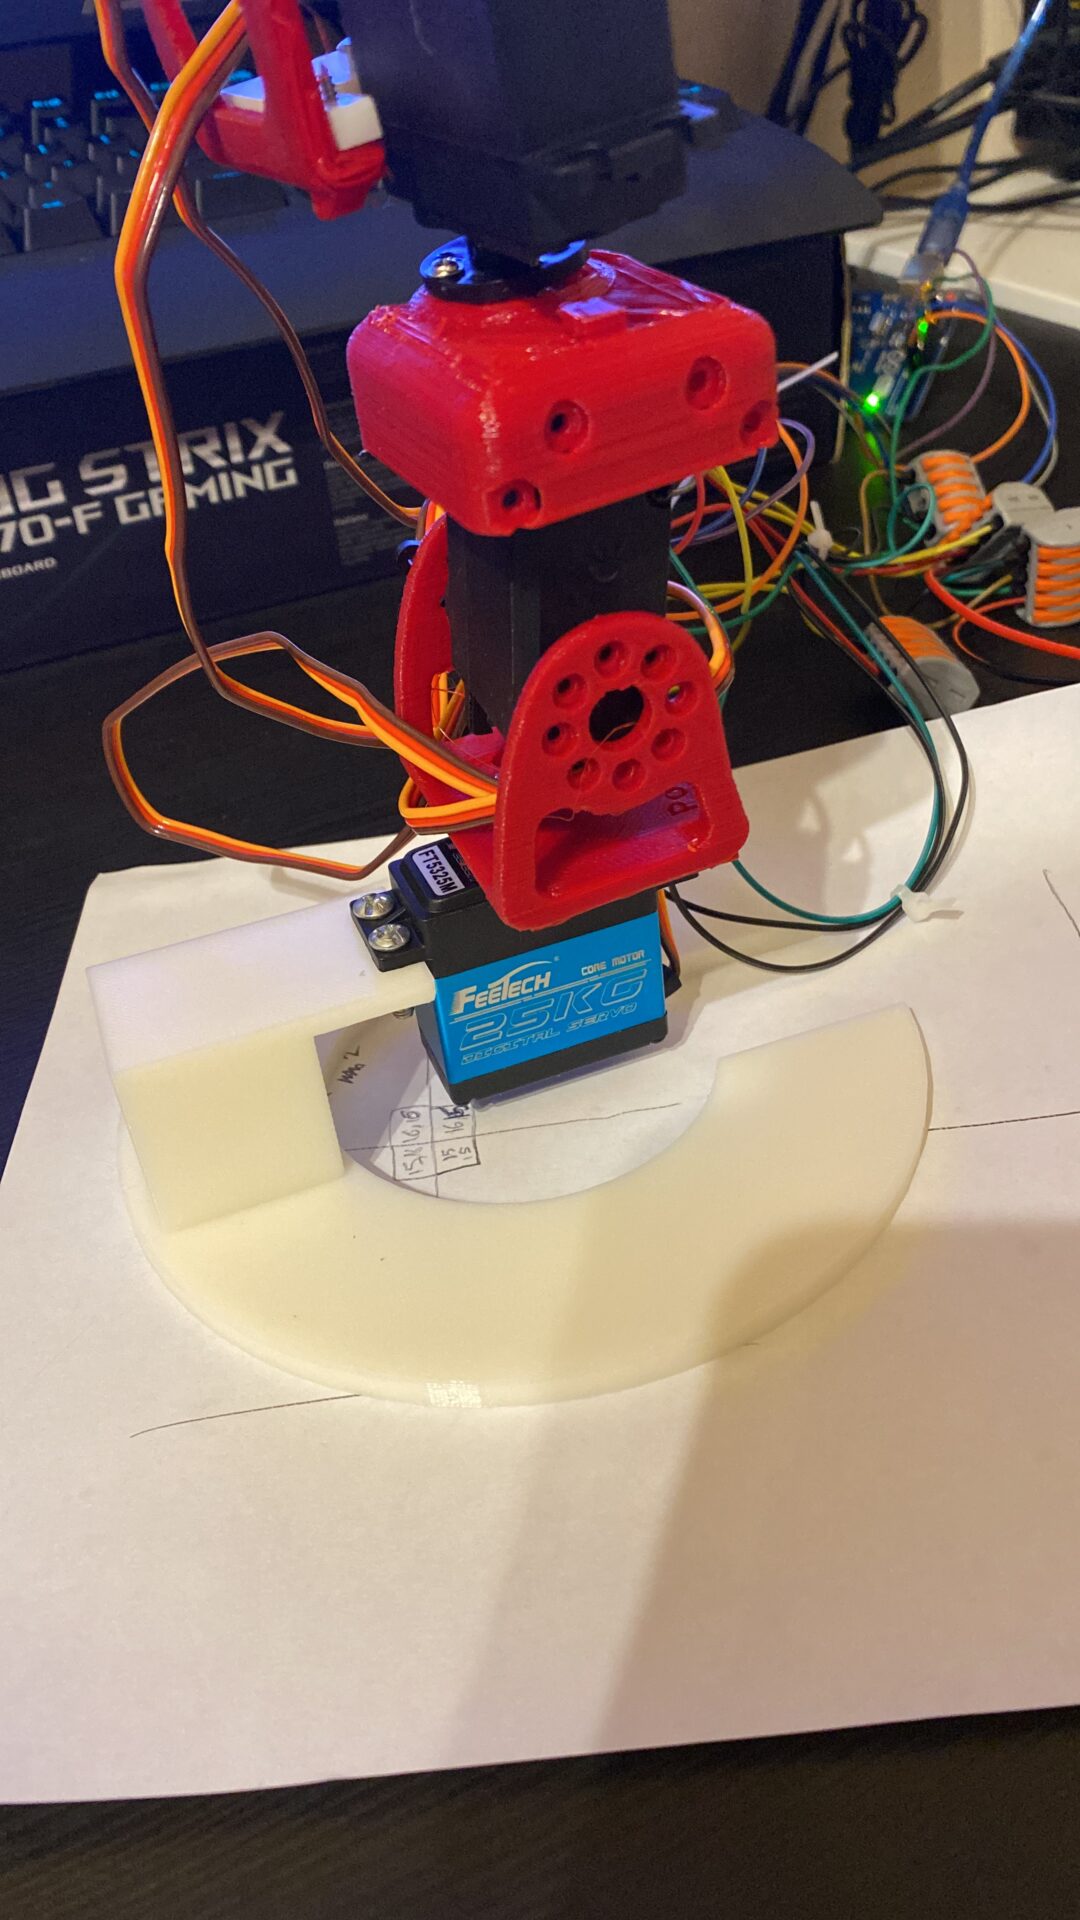
Based on the open source Poppy Humanoid Robot, the arm joints where 3D printed and used as a practical exercise on how to develop a robotic arm with joint manipulation through inverse and forward kinematics.
The code for the simulation was developed on Matlab and subsequently simulation using Simulink. The 3D printed robotic arm was assembled with suitable servo motors, and the control code was developed on an Arduino Uno board. Given a point in space, the robotic arm can be seen in realtime successfully following the expected trajectory, similar to the one simulated on Simulink