Autonomous Driving of an Ackerman-Like Vehicle
Co-development & Implementation: Omar Mostafa (2022)
Tools used: ROS, Gazebo, Python, Raspberry-pi, Breadboard, Jumper cables, Electric design, Software Engineering, 3D modeling, Linux.
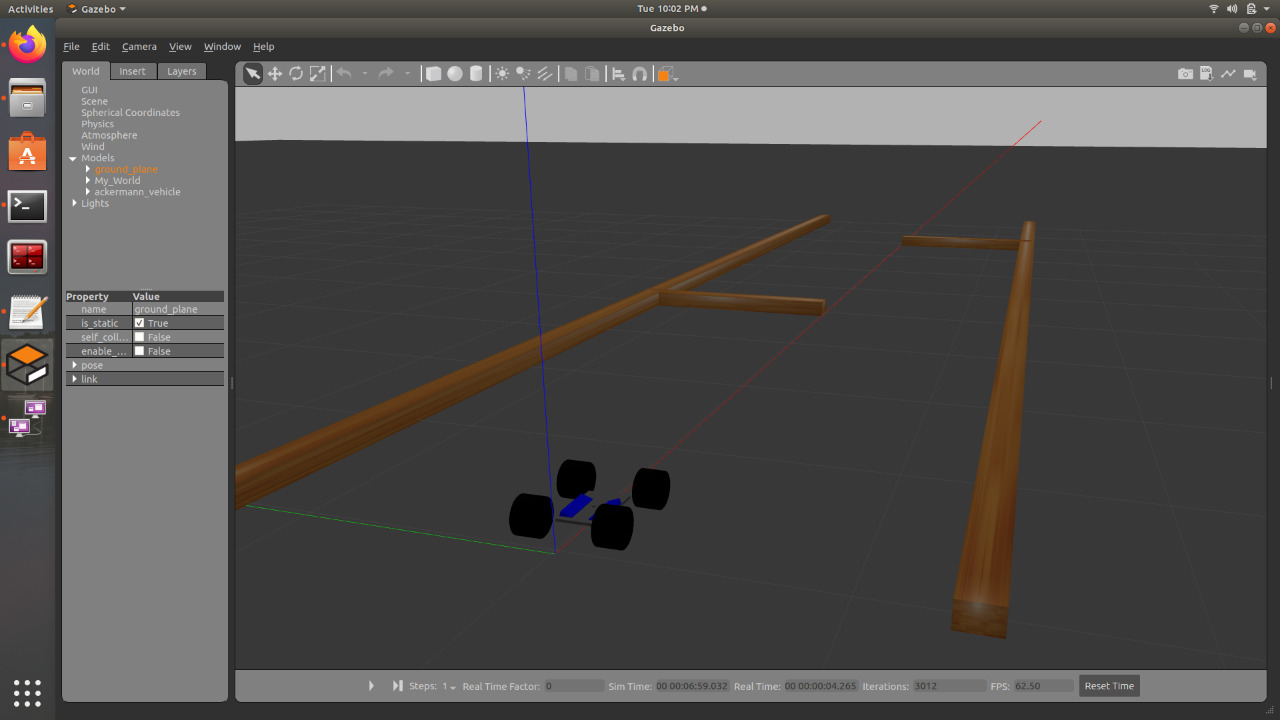
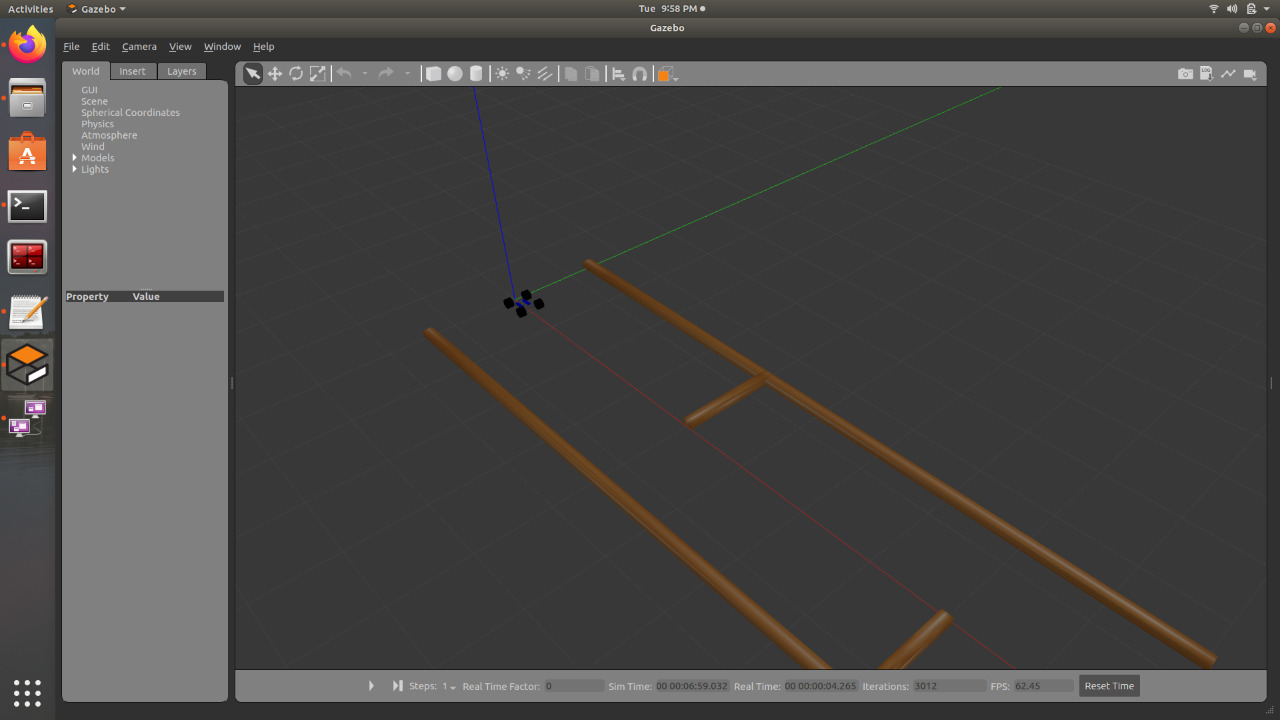
The autonomous driving and obstacle avoidance vehicle was part of the Autonomous systems team project, produced to gain practical experience working with ROS, as well as simulation world building platofrms namely Gazebo.
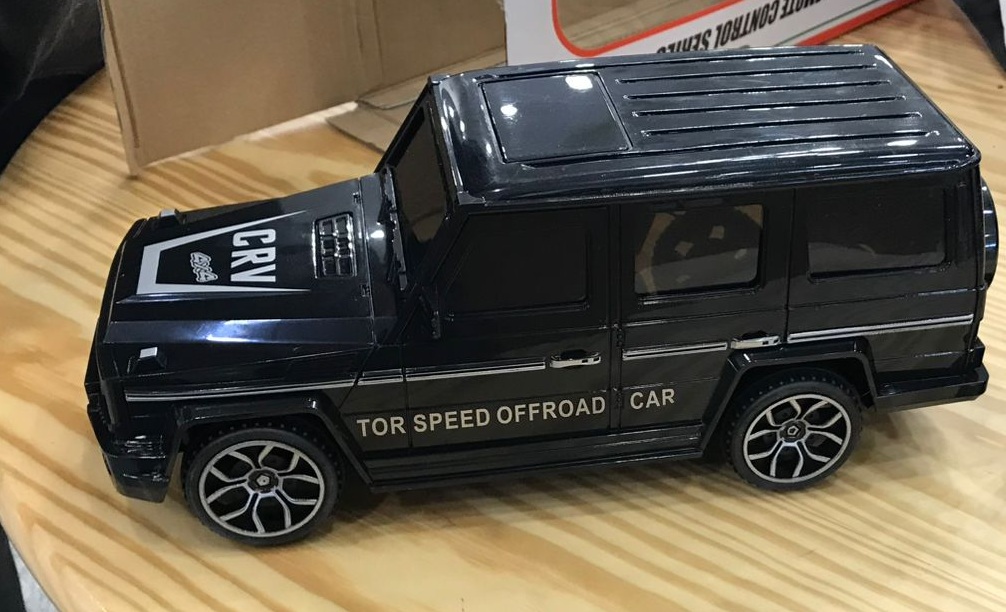
The project contains a hardware development section on a RC car model with 1:14 scale, and a software development and simulation section, done using ROS, Python and Gazebo.
The collision avoidance is built on top of a predictive algorithm developed that utilizes Kalman filters for predicitve modeling and object velocity predictions.