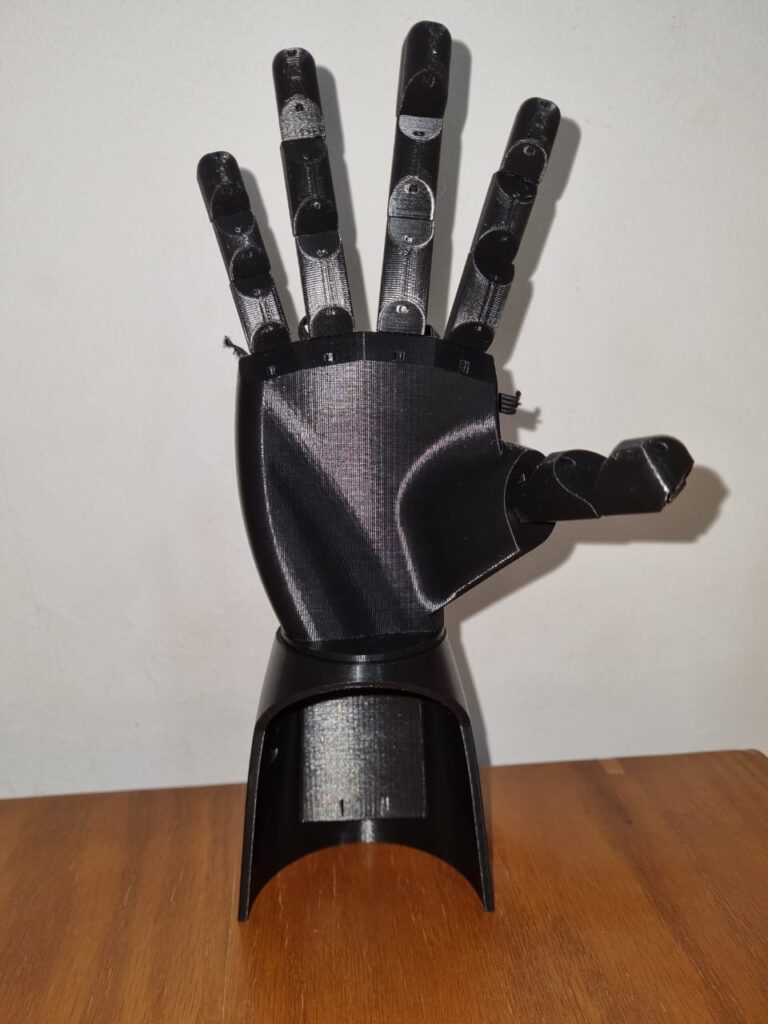
Hand Mimicker Robot
Software/Circuitry co-development: Omar Mostafa (2021)
Tools used: OpenCV, Python, Arduino, Breadboard, Jumper cables, Electric design, Software Engineering.
The hand mimicker robot was part of a Image Processing course team project to experiment with different image processing techniques.
The mimicker software is based on a color detection methodology where each finger is manipulated by a string connected to a servo motor, based on the amount of new color detected pixels in the transition frame.
The color can be calibrated in realtime, allowing for the support of different light conditions. The degree of rotation of the servo motor affects how clenched each finger is, and is affected by the count of detected target pixels.